Undersea training, passive sensing and ship navigation for maritime operations.
Maritime systems
EMATT simulates submarine sound and movement for anti-submarine warfare training. HAVS detects underwater sources and determines their bearing. Cel-Nav provides ships with position and true-north heading independently of GNSS.
ASW training target
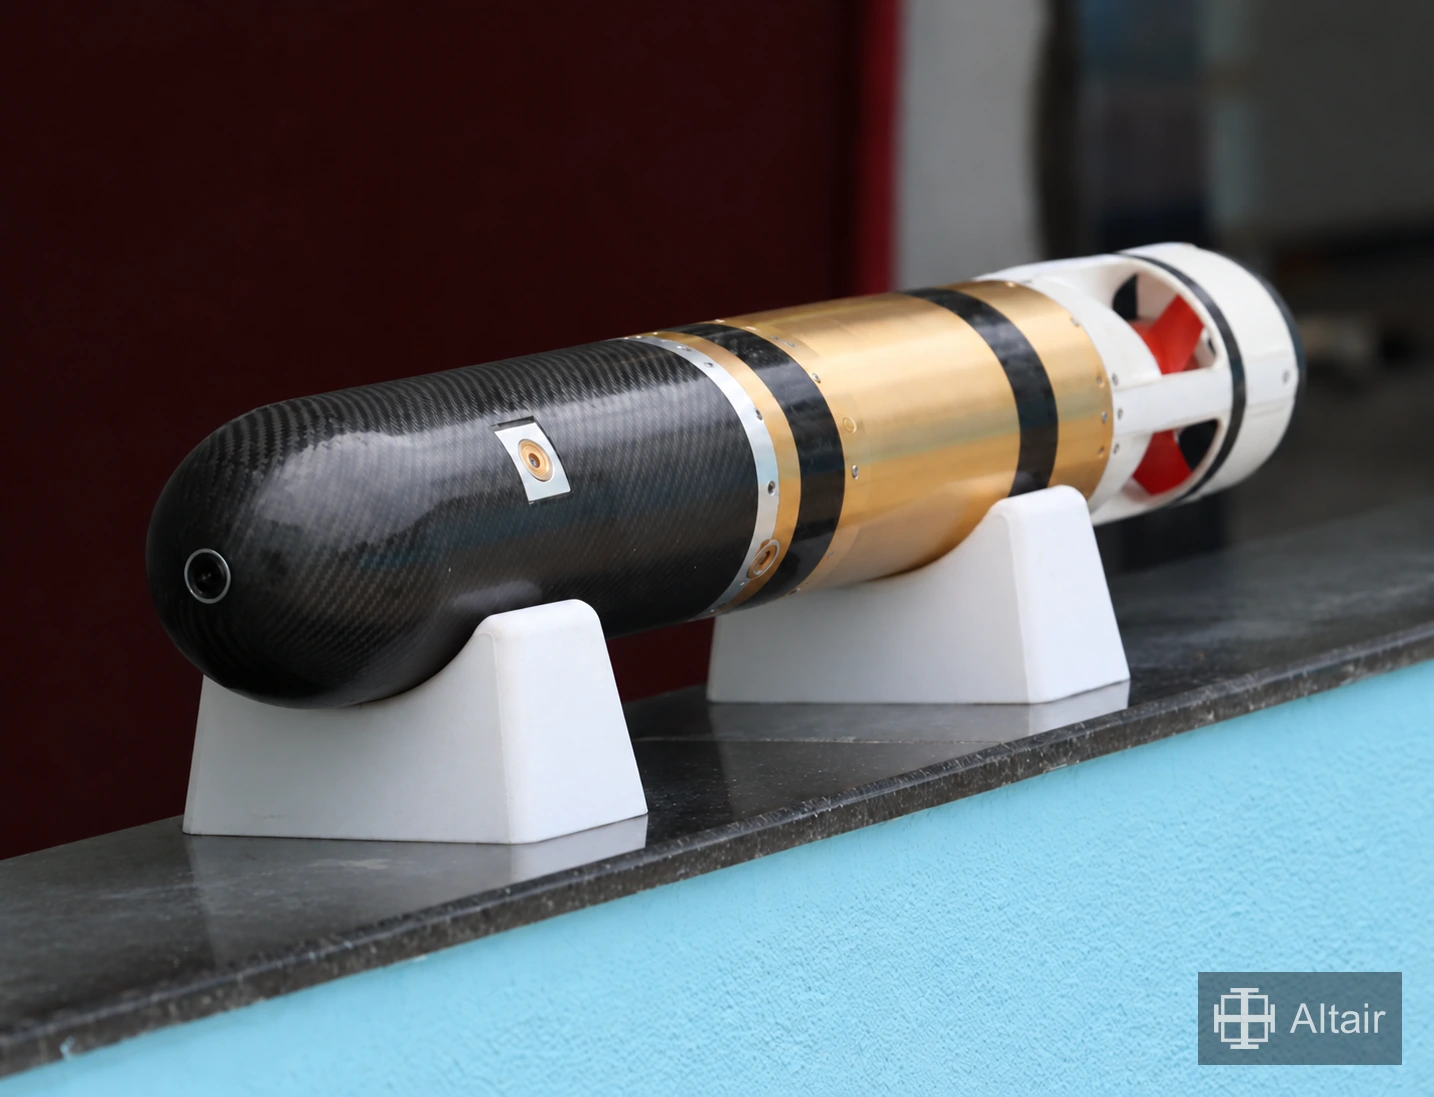
EMATT
An expendable, battery-powered underwater target that simulates submarine sound and movement for anti-submarine warfare training. NATO A-size compatibility requires no platform modification.
EMATT lets training teams programme speed, depth, heading and acoustic profiles to represent submarine behaviour. Passive acoustic and echo modes support different training scenarios, with ship-launched Mk1 and air-launched Mk2 configurations.
Maximum speed
8 kn
Maximum depth
180 m
Endurance
6 h
Weight
<10 kg
Technical details +
914 × 124 mm body; 18–24 nmi mission endurance.
Passive acoustics: 1–3 kHz with variable power. Echo mode: 3–13.5 kHz, ranging error under 150 yd.
Programmable speed, depth, heading and acoustic profile.
Mk1 ship-launched; Mk2 air-launched with MAD up to 25 m.
Operates up to Sea State 4; sinks automatically after the mission.
Hydro-acoustic vector sensor
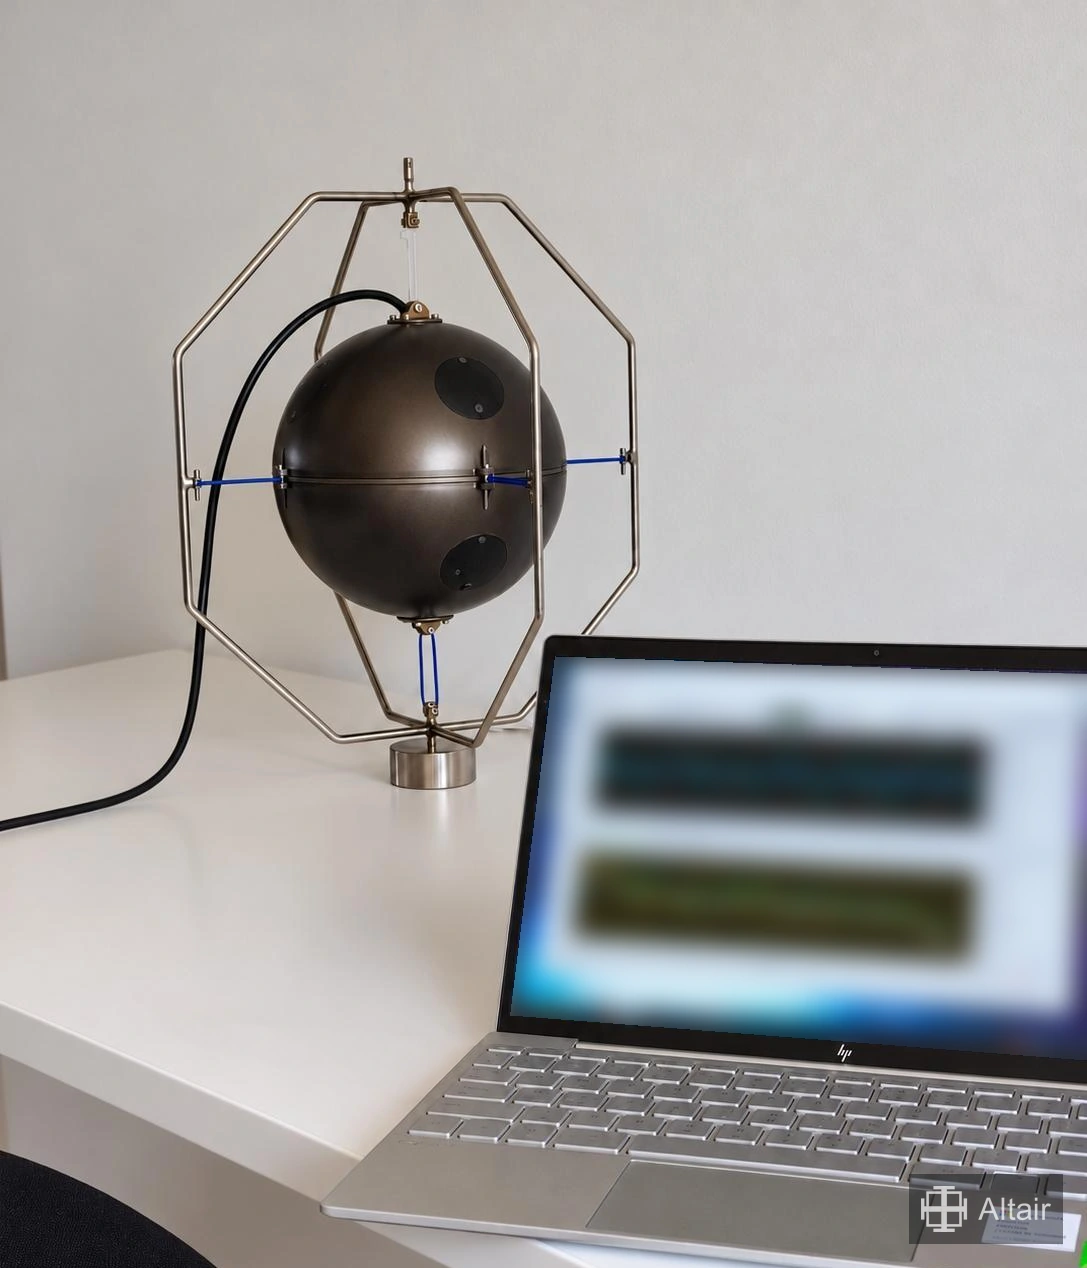
HAVS
Detects ultra-low-frequency underwater sources and determines their bearing from a single unit. Networked nodes triangulate the source for passive surveillance, localisation and tracking.
A single HAVS unit provides direction-of-arrival information without a hydrophone array, while networked nodes can triangulate a source. LOFAR detection, waterfall and bearing plots, and AI/ML anomaly detection support passive localisation and multiple-target tracking.
Frequency range
250–2000 Hz
Bearing accuracy
±5°
Tested depth
300 m
Direction of arrival
1 unit
Technical details +
Bearing detection from a single unit, with no hydrophone array.
LOFAR ultra-low-frequency detection and multiple-target tracking.
Waterfall and bearing-plot displays with AI/ML anomaly detection.
Ship navigation aid
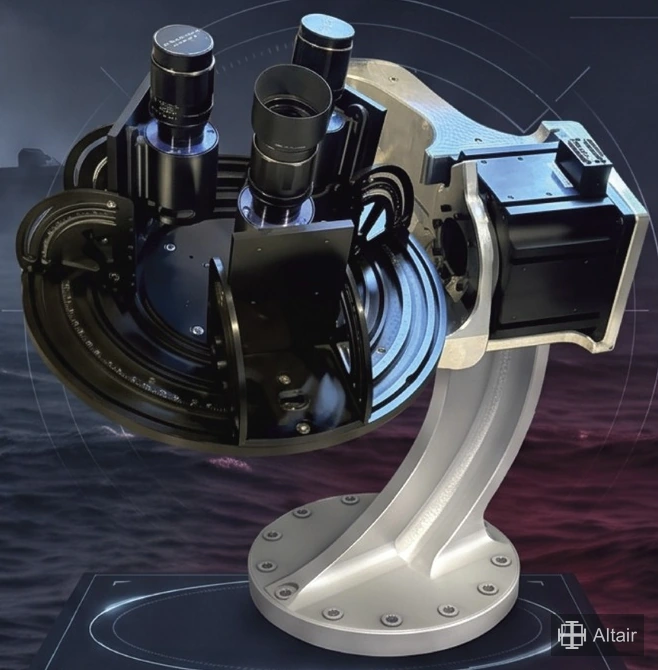
Cel-Nav
A celestial navigation aid for ships that fixes position and true-north heading from the stars by night and the Sun by day, with no GNSS to jam or spoof.
Intended as a ship navigation aid, Cel-Nav uses a star channel at night and a Sun channel by day, mounted on a two-axis stabilised platform with FOG INS. This passive approach provides position and true-north heading without depending on satellite navigation.